UAV Navigation enhances visual navigation system for GNSS-denied flight
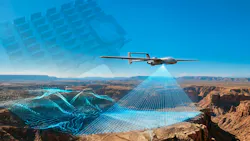
MADRID - UAV Navigation-Grupo Oesía has updated its VNS01 Visual Navigation System with terrain-referenced navigation (TRN) and satellite map matching algorithms designed to maintain positioning accuracy during global navigation satellite system (GNSS) outages.
The software update adds two positioning references to the VNS01, which combines visual odometry with other navigation techniques to support autonomous aircraft when satellite navigation signals are unavailable or compromised.
Satellite map matching compares onboard camera images with preloaded satellite imagery. By matching geographic features such as roads, rivers, and coastlines, the system calculates absolute position corrections to compensate for inertial navigation drift.
TRN provides an additional positioning reference by correlating in-flight altitude measurements with preloaded digital elevation models. This approach enables the system to estimate aircraft position when visual references are limited or unavailable.
Combining visual odometry, satellite map matching, and TRN is designed to limit positioning error accumulation during prolonged GNSS outages, including on routes the aircraft has not previously flown. UAV Navigation-Grupo Oesía reports that, under favorable operating conditions, the system can constrain positioning errors to approximately 30 meters regardless of distance traveled.
The enhancements are intended for uncrewed aircraft systems (UAS) operating in environments affected by GNSS jamming, spoofing, and other satellite-navigation disruptions. The company develops guidance, navigation, and control systems for autonomous aerial platforms.
For more information, visit www.uavnavigation.com.